Engineering the Deep: Designing, Building and Operating Underwater ROVs:
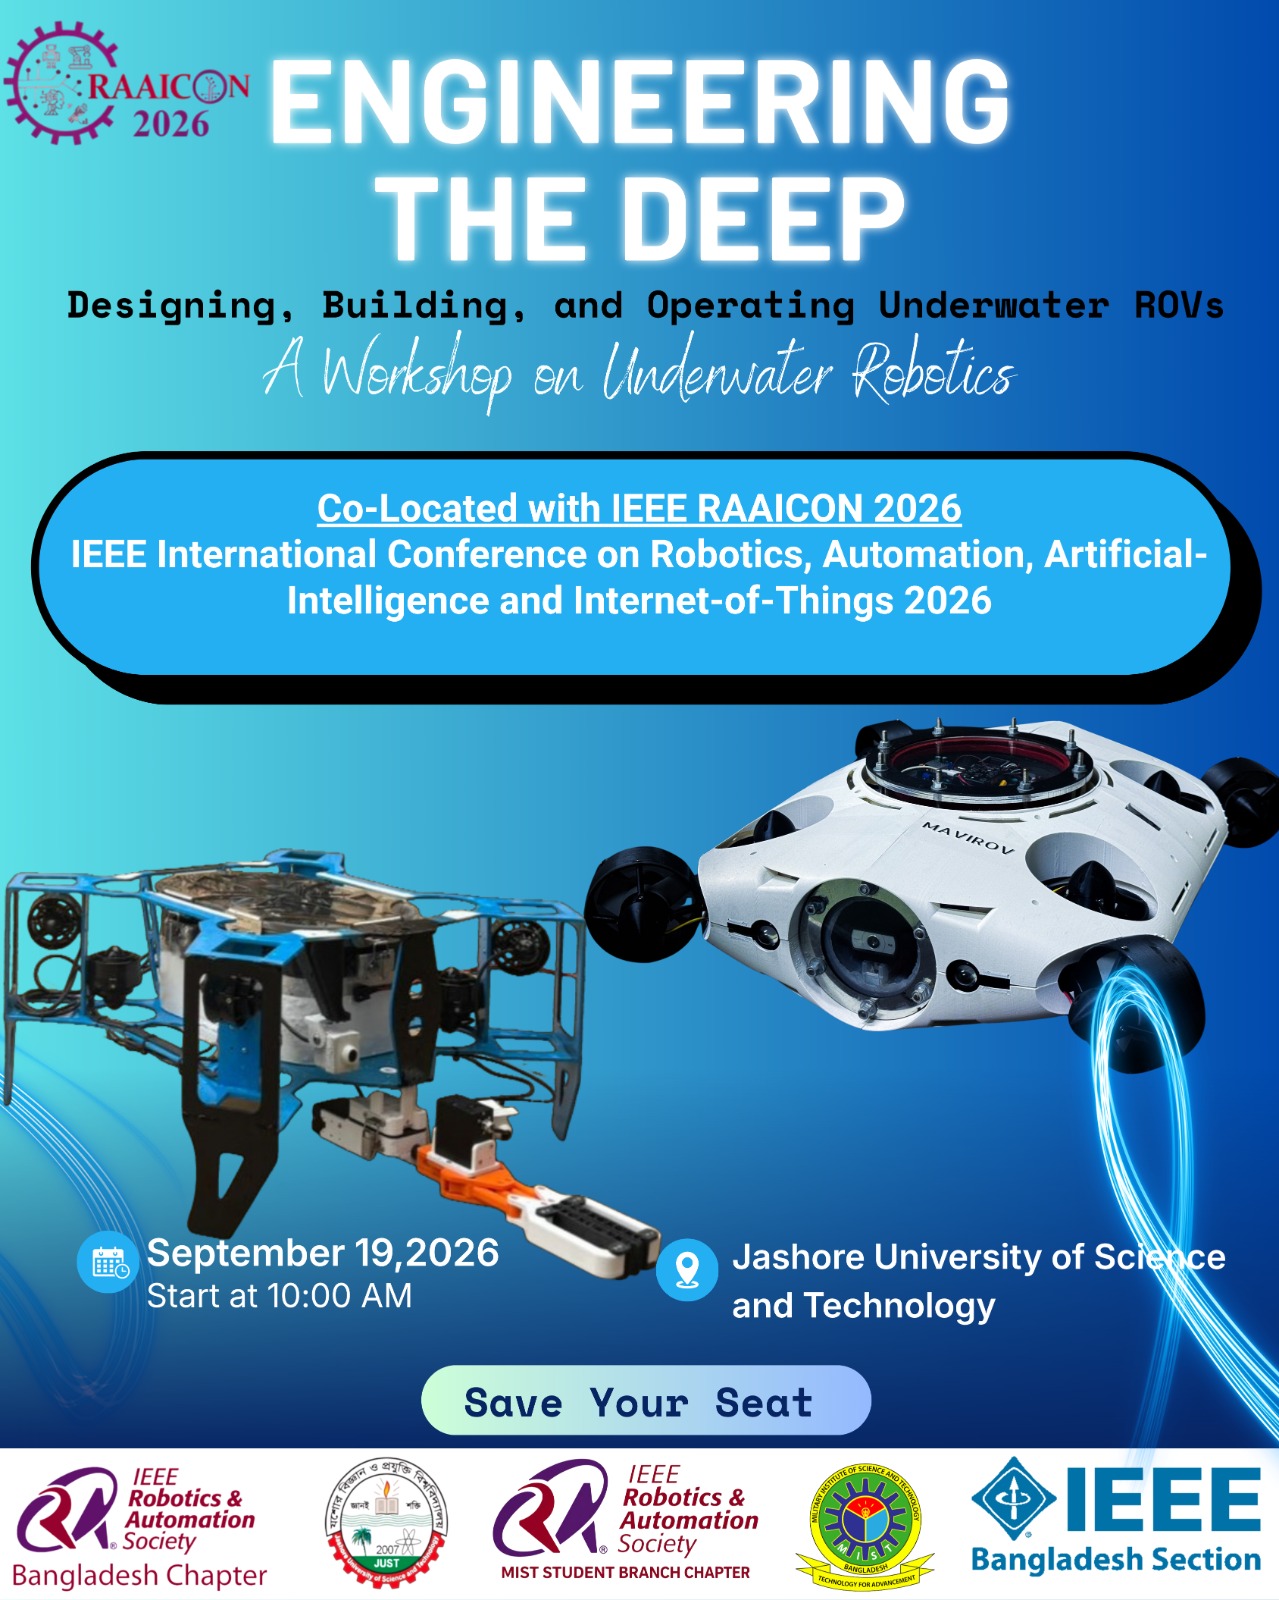
A Workshop on Underwater Robotics:
Team MIST MAVIROV, the Military Institute of Science and Technology’s first underwater robotics team and members of the IEEE MIST Robotics and Automation Society (RAS) Student Branch Chapter, presents a 2-hour technical workshop on underwater robotics, co-located with IEEE RAAICON 2026. The team recently won the Pioneer Class of the MATE ROV World Championship 2026, recording the highest points ever achieved in that class, and this session distills that competition-tested engineering into a structured technical discussion.
The workshop covers the three core subsystems of a remotely operated vehicle (ROV):
Mechanical: frame design and material selection for submerged operation, buoyancy and ballasting for neutral trim, gasket sealing and enclosure design for waterproofing, thruster configuration, and manipulator/gripper mechanisms.
Electrical & Power: power distribution and integrity within a sealed enclosure, motor drivers and electronic speed controllers (ESCs), tether design for power delivery and signal integrity over distance, thermal management, and electromagnetic interference (EMI) mitigation in a confined underwater housing.
Software, Controls & Perception: ground control station (GCS) and topside telemetry architecture, closed-loop control for depth, heading, and station-keeping, and onboard computer vision for underwater object detection and navigation.
A dedicated segment addresses the practical challenges of deploying embedded systems in real hardware applications — debugging sensor and actuator faults in a sealed, inaccessible enclosure, handling power brownouts and signal noise under real operating loads, managing firmware reliability over a tethered link, and the iterative testing-and-fixing process required to take an embedded system from a working prototype to a field-reliable one under competition conditions.
Each segment is grounded in actual design decisions and trade-offs made on the team’s competition ROV, supported by recorded footage from pool testing and world championship runs. The session addresses engineering constraints specific to underwater systems — corrosion resistance, limited visibility, tethered communication, and pressure/buoyancy management — that distinguish ROV design from aerial or ground robotics.
Aimed at students, researchers, and young professionals in robotics, mechatronics, embedded systems, or marine/field robotics, the workshop offers a research-informed, competition-validated perspective on a still-nascent field in Bangladesh.
Instructors:
- Sheikh Tanvir Islam Udoy – Chair (IEEE RAS MIST SB Chapter) (Level 4 EEE MIST)
- Md. Rokonuzzaman Shaad – General Secretary (IEEE RAS MIST SB Chapter) (Level 4 EEE MIST)
- Areeb Ayman Haq – Webmaster (IEEE RAS MIST SB Chapter) (Level 4 EEE MIST)